

Open source software stack for the development of robotic applications.
Office Address
Plaza de la Encina 10-11, Núcleo 4, 2ª Pl.
28760 Tres cantos - Madrid (España)
Vulcanexus HRI introduces a practical Human-Robot Interaction framework for ROS 2, helping developers build more human-aware robotic systems through perception, communication and interaction capabilities.
Vulcanexus is thrilled to announce the release of the new Vulcanexus Jazzy Jolo V4.1.0, which supports ROS 2 Jazzy Jalisco and brings updates and new features to its tools.
Get your Human-Robot Interaction (HRI) solution funded
Vulcanexus is excited to share that the ARISE Open Call, launching this October, offers your organization a unique opportunity to develop innovative HRI solutions with the chance to receive up to €200,000 in funding.
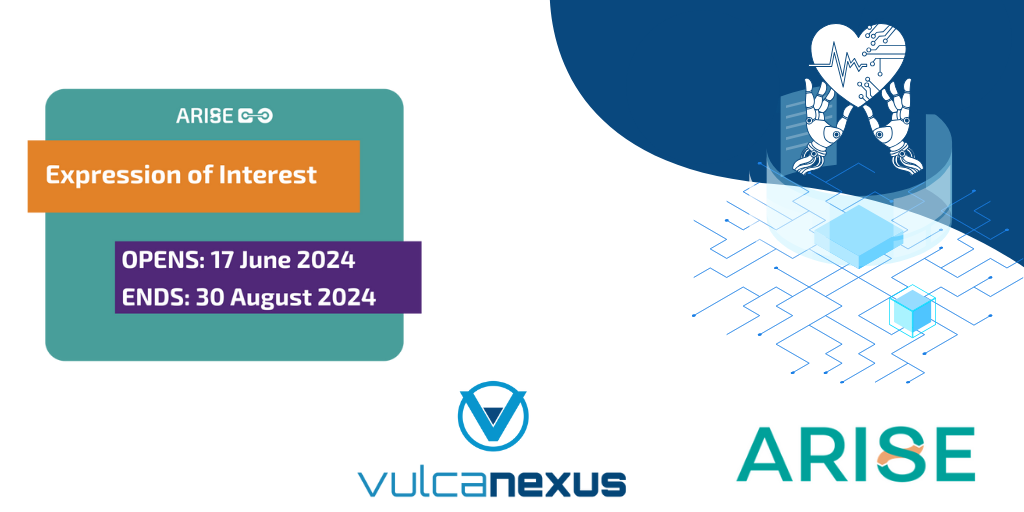
As Vulcanexus is part of the ARISE consortium, we are happy to announce the Expression of Interest – the initial phase of ARISE's 1st Open Call.
Vulcanexus is thrilled to announce the release of the new Vulcanexus Iron Imagination v3.2.0, which supports ROS 2 Iron and brings many updates and new features to its tools.
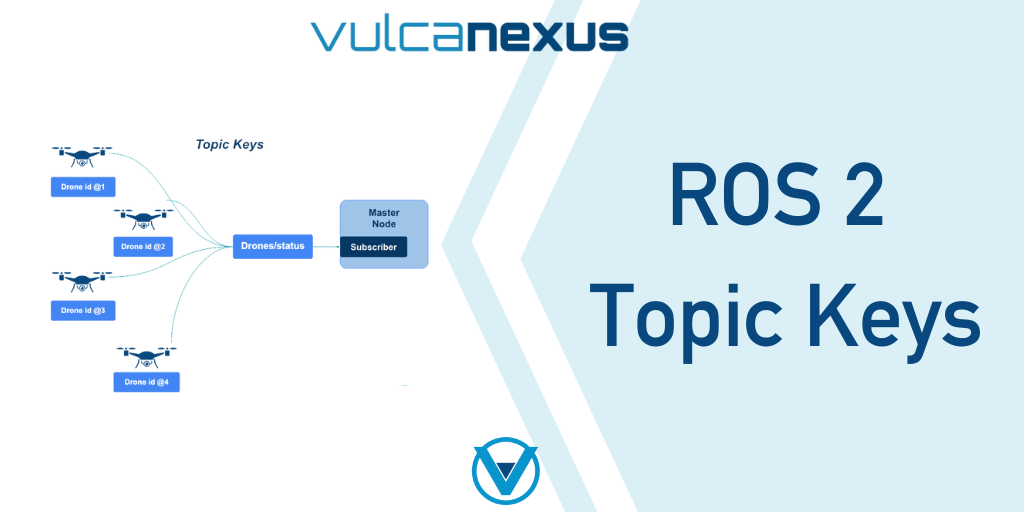
Exposing Topic Keys in Vulcanexus revolutionizes robotic systems' efficiency and scalability by streamlining communication and resource utilization, reducing overhead, and enhancing data distribution.
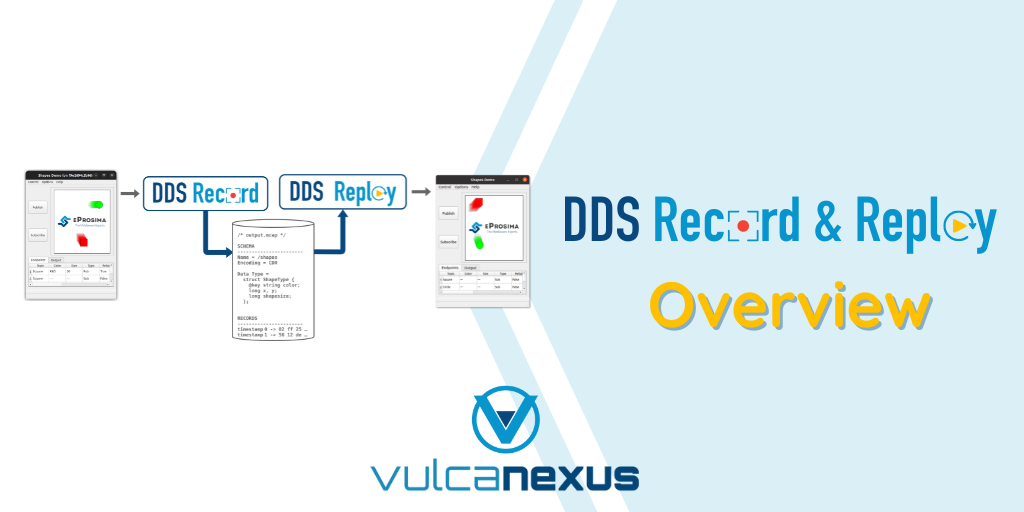
ROS 2 Record & Replay (a.k.a DDS Record & replay) enables users to save and replay DDS data, allowing for better and more accurate testing, debugging & analysis.
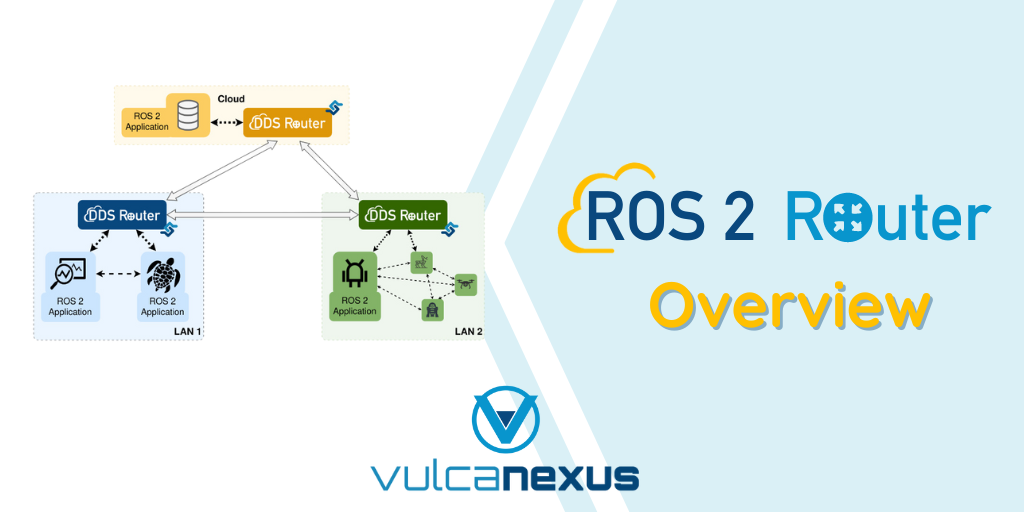
ROS 2 Router (a.k.a. DDS Router) is an end-user software application shipped with Vulcanexus Cloud that enables the connection of distributed ROS 2 networks that would otherwise be isolated. This solution offers an easy deployment due to a configurable modular system.
Vulcanexus releases a new Humble 2.4.0 version with many new components' features, improvements, and bug fixes.
Open source software stack for the development of robotic applications.
Plaza de la Encina 10-11, Núcleo 4, 2ª Pl.
28760 Tres cantos - Madrid (España)